Personal experiment / Doly
Doly — Robotics
Outcome & decision
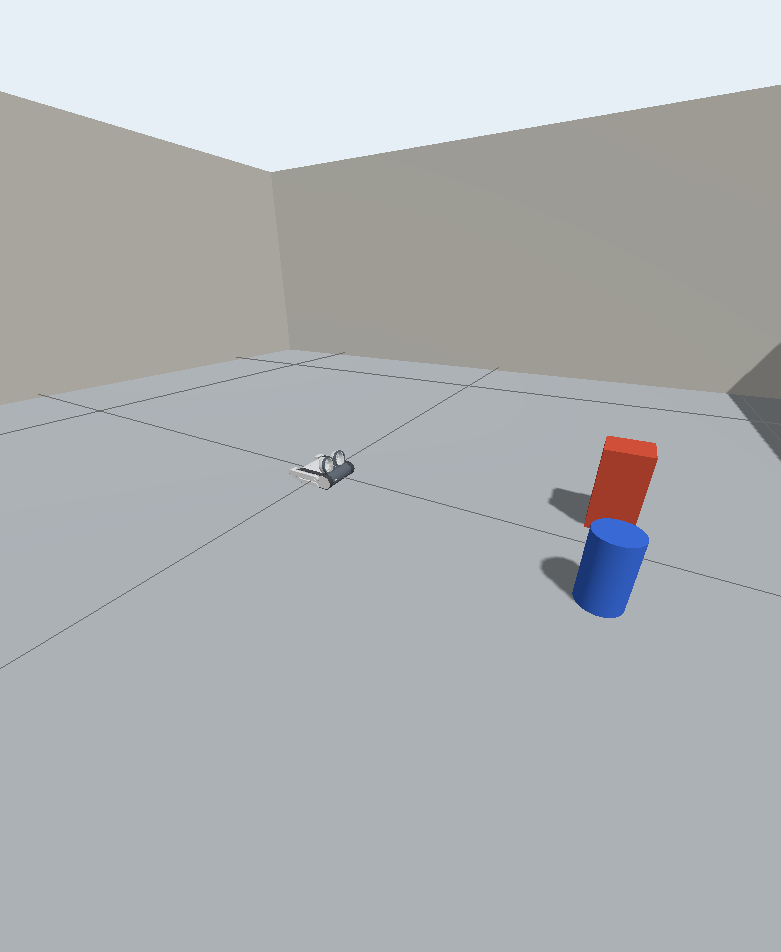
An exploratory robotics project combining Gazebo simulation, ROS 2 sensor recording, and initial localization tests. A foundation for further experiments with Doly.
- My responsibility
- Simulation setup, sensor integration, and evaluation · AI-assisted development
- Project scope
- Early-stage simulation work; localization remains experimental
Evidence basis. Recorded sensor data, replay checks, trajectory plots, and a nine-case VIO matrix
What I built
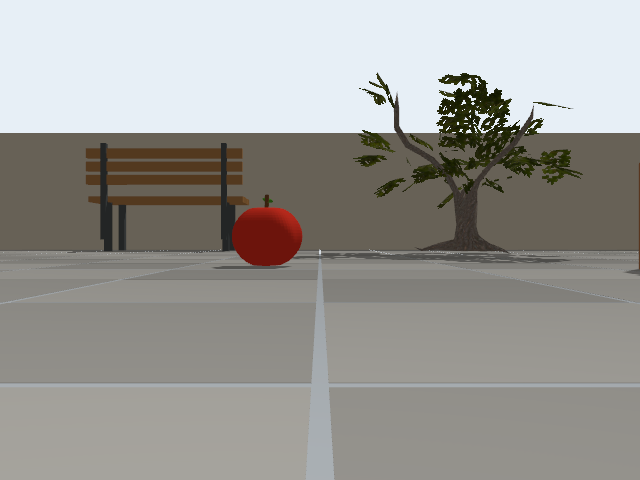
Set up a Doly model in Gazebo and connected camera, IMU, wheel feedback, and simulation time through ROS 2. Organized sensor checks, recording, and replay with AI-assisted implementation, then used the camera and IMU inputs for initial OpenVINS localization tests.
What I tested
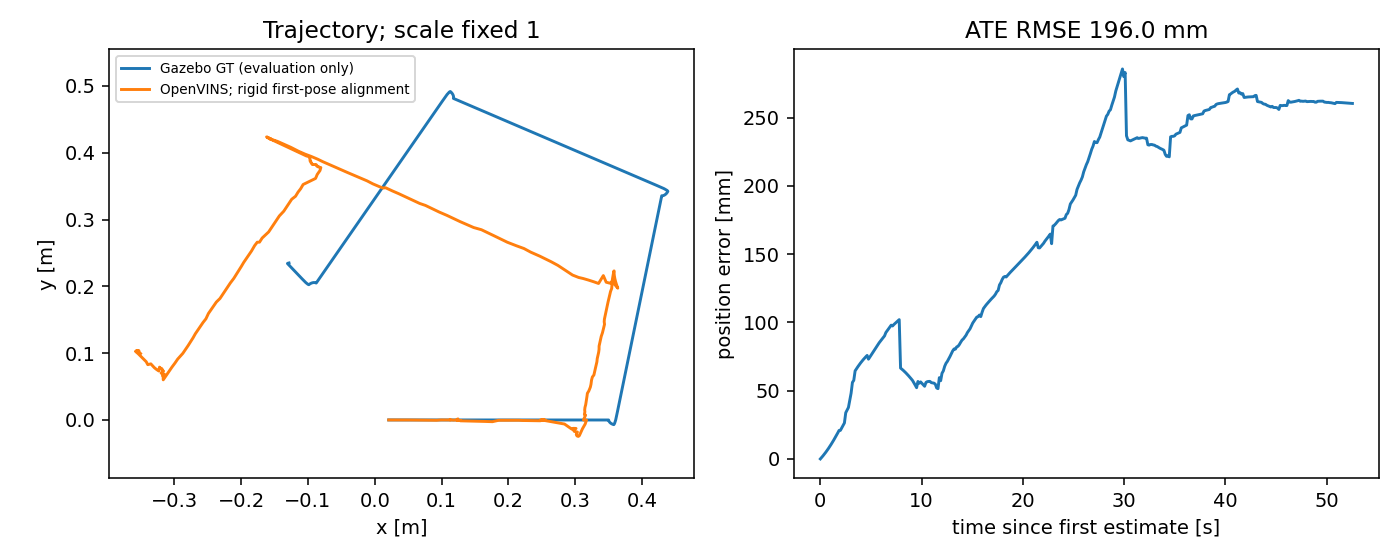
Sensor preparation passed 172 offline tests, and two recorded acquisitions passed replay checks. OpenVINS passed 3 of 9 evaluation cases: one short run reached 5.48 mm trajectory error, while a meter-scale route drifted to 19.60 cm. Gazebo ground truth was used only for offline scoring.
Current scope & future plans
Known-map navigation was also explored in simulation; its latest strict retest passed 4 of 6 tasks. Physical-robot navigation and the connection to Voice Agent remain future work.
Planned next steps are to improve OpenVINS initialization and repeatability, explore visual SLAM for mapping and localization, and verify device sensor data. A later LLM + robotics experiment would connect Voice Agent to bounded robot tools with execution feedback. These are exploration plans, not completed capabilities.
Tools & methods
Visuals from the project archive. Doly CAD: DOLY / Levent Erenler, CC BY-NC-SA 4.0. Scene tree: OSRF, CC BY 3.0. Image credits & licenses ↗